Hi, I'm Daniel Jacquet

Robotics Engineer

I work on manipulation, motion planning, and robot learning. From bare-metal firmware to learned policies.

What I do

  • Manipulation and motion planning
    • Dual-arm assembly planning from CAD in Isaac Sim
    • A full UR10e assembly planned in 59 s with cuRobo
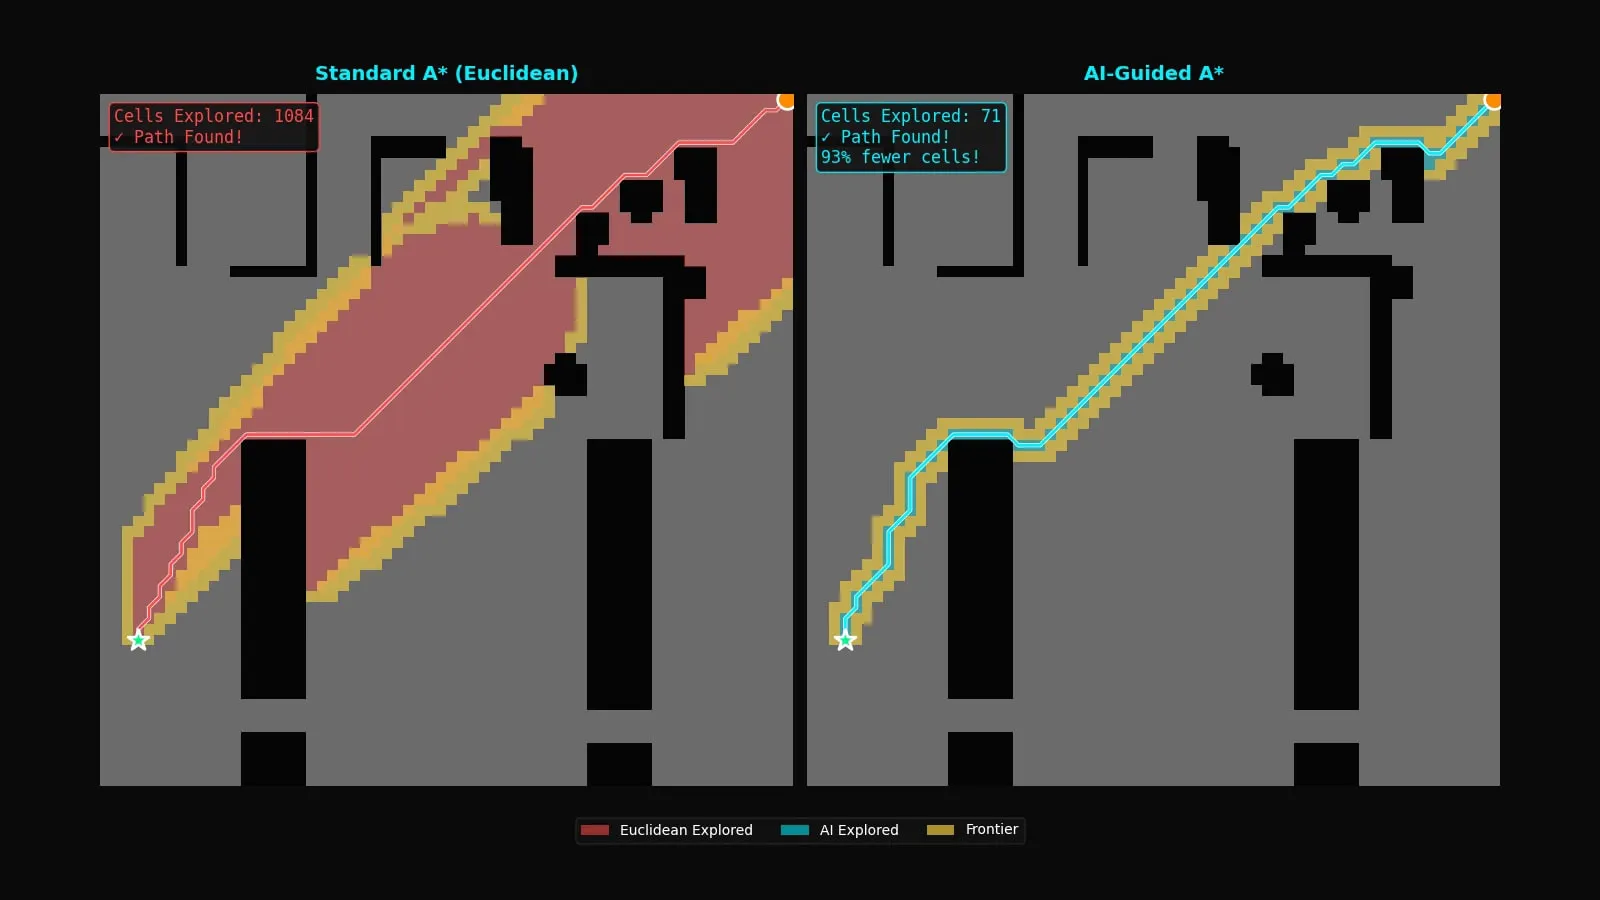
    • Learned A* heuristics that cut search nodes by 89.7%
  • Robot learning
    • Insertion policies learned from expert demonstrations
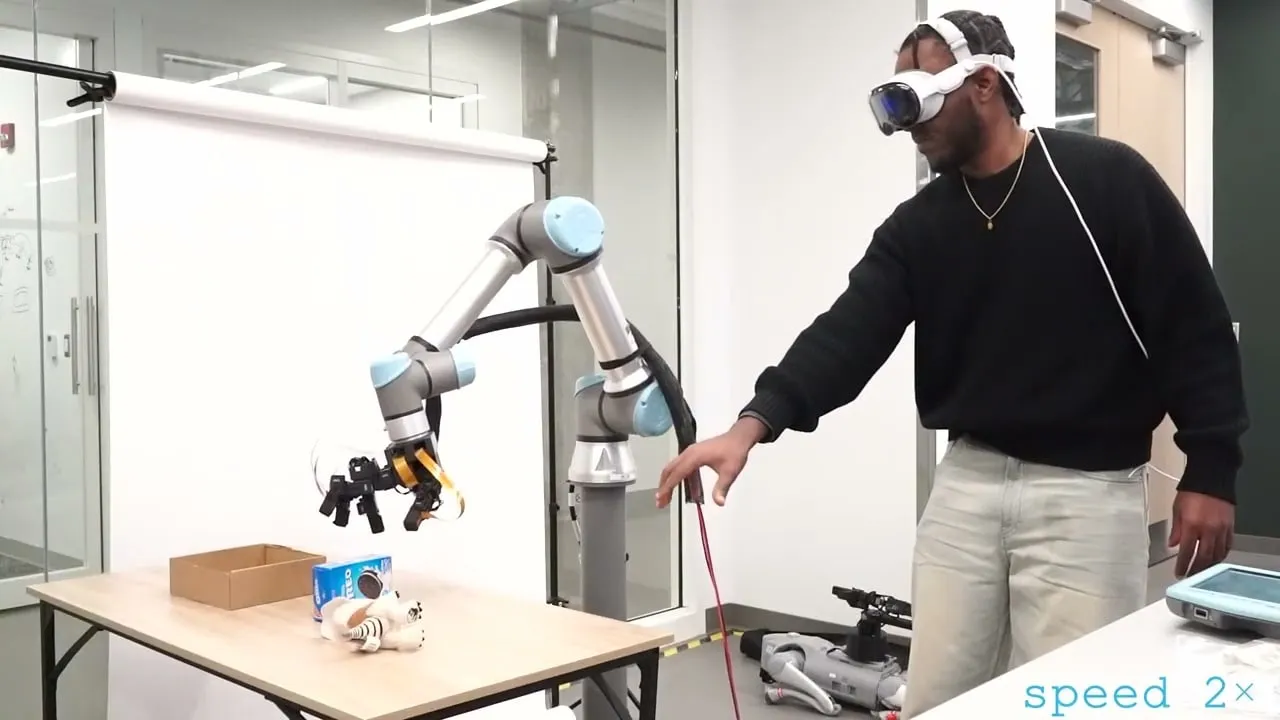
    • Teleoperation that records demonstrations for vision-language-action training
    • Full-hand tactile sensing on the 16-DOF LEAP Hand
  • Embedded systems and hardware
    • Bare-metal C firmware for sensorless BLDC commutation on STM32
    • A custom motor controller PCB designed in KiCad
    • A C++ device framework with a polymorphic HAL

Selected work

Work experience

  • Internship at Magna International, Advanced Robotics R&D

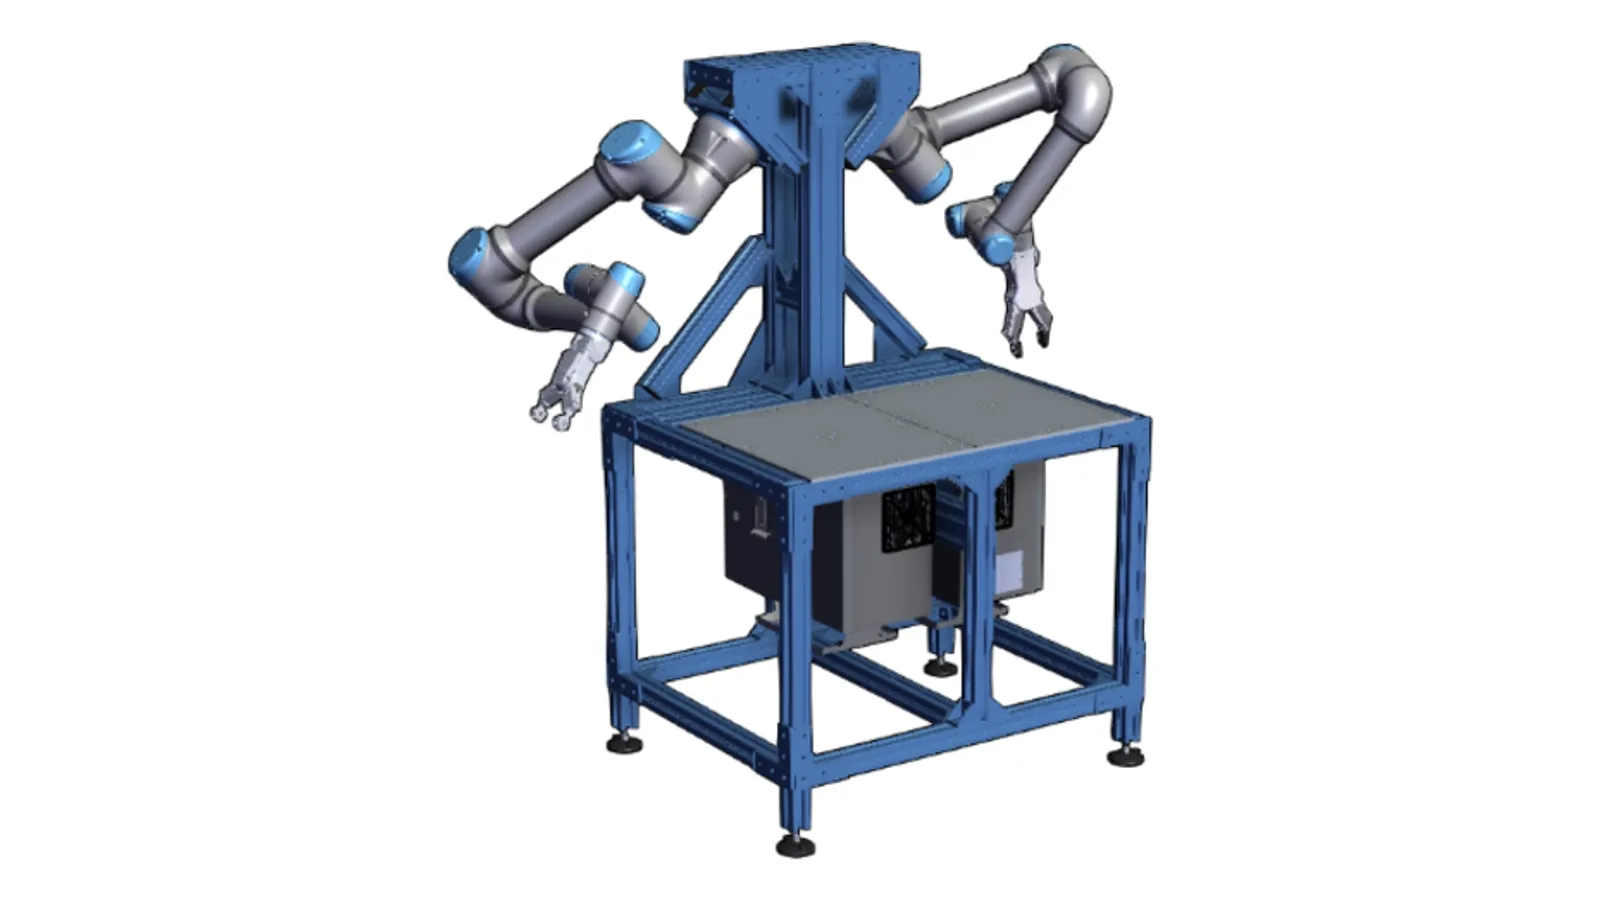
    Dual-arm assembly R&D: from CAD to a learned insert

    Research and development internship at Magna. A dual-arm pipeline in Isaac Sim that plans a full production assembly in 59 seconds, then hands the last millimeters of insertion to a learned policy.
    3 min read

  • Research at Mars Lab, Purdue University

    Dexterous manipulation with full-hand tactile sensing

    Graduate research at the Purdue Mars Lab. I design manipulation tasks, 3D-printed test fixtures, and sensor fusion setups to give a 16-DOF robotic hand a sense of touch.

    2 min read

School projects

  • School project at Purdue University

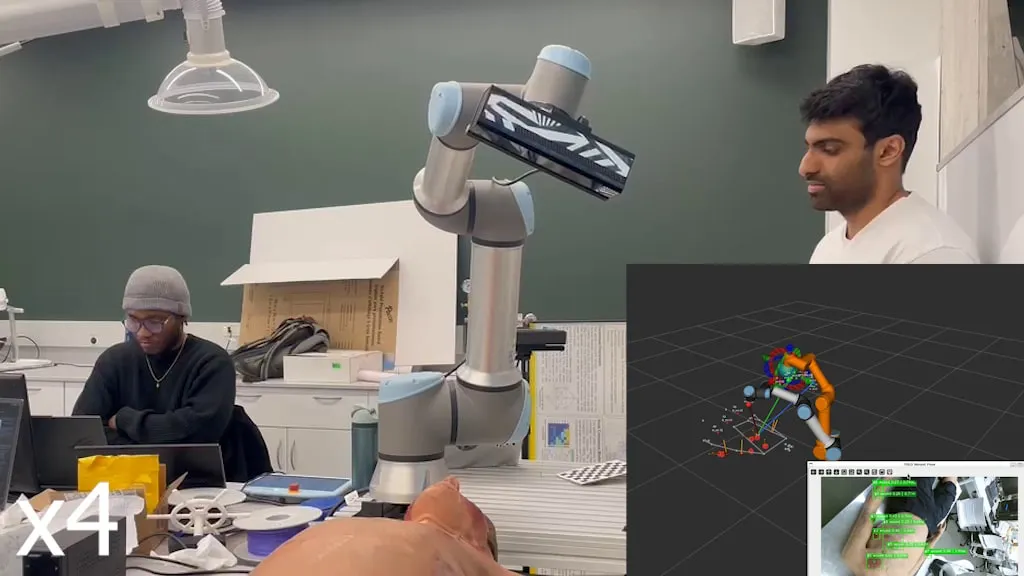
    Vision-guided autonomous wound scanning and treatment

    A UR16e finds wounds on a patient by itself, measures them in 3D, writes a clinical report, and holds a perpendicular treatment pose while the patient moves.

    3 min read

  • School project at Purdue University

    FastPath: learned heuristics for A*

    A machine learning model that speeds up A* pathfinding by predicting obstacle-aware heuristics, cutting search time significantly.

    3 min read

Personal projects

  • Personal project

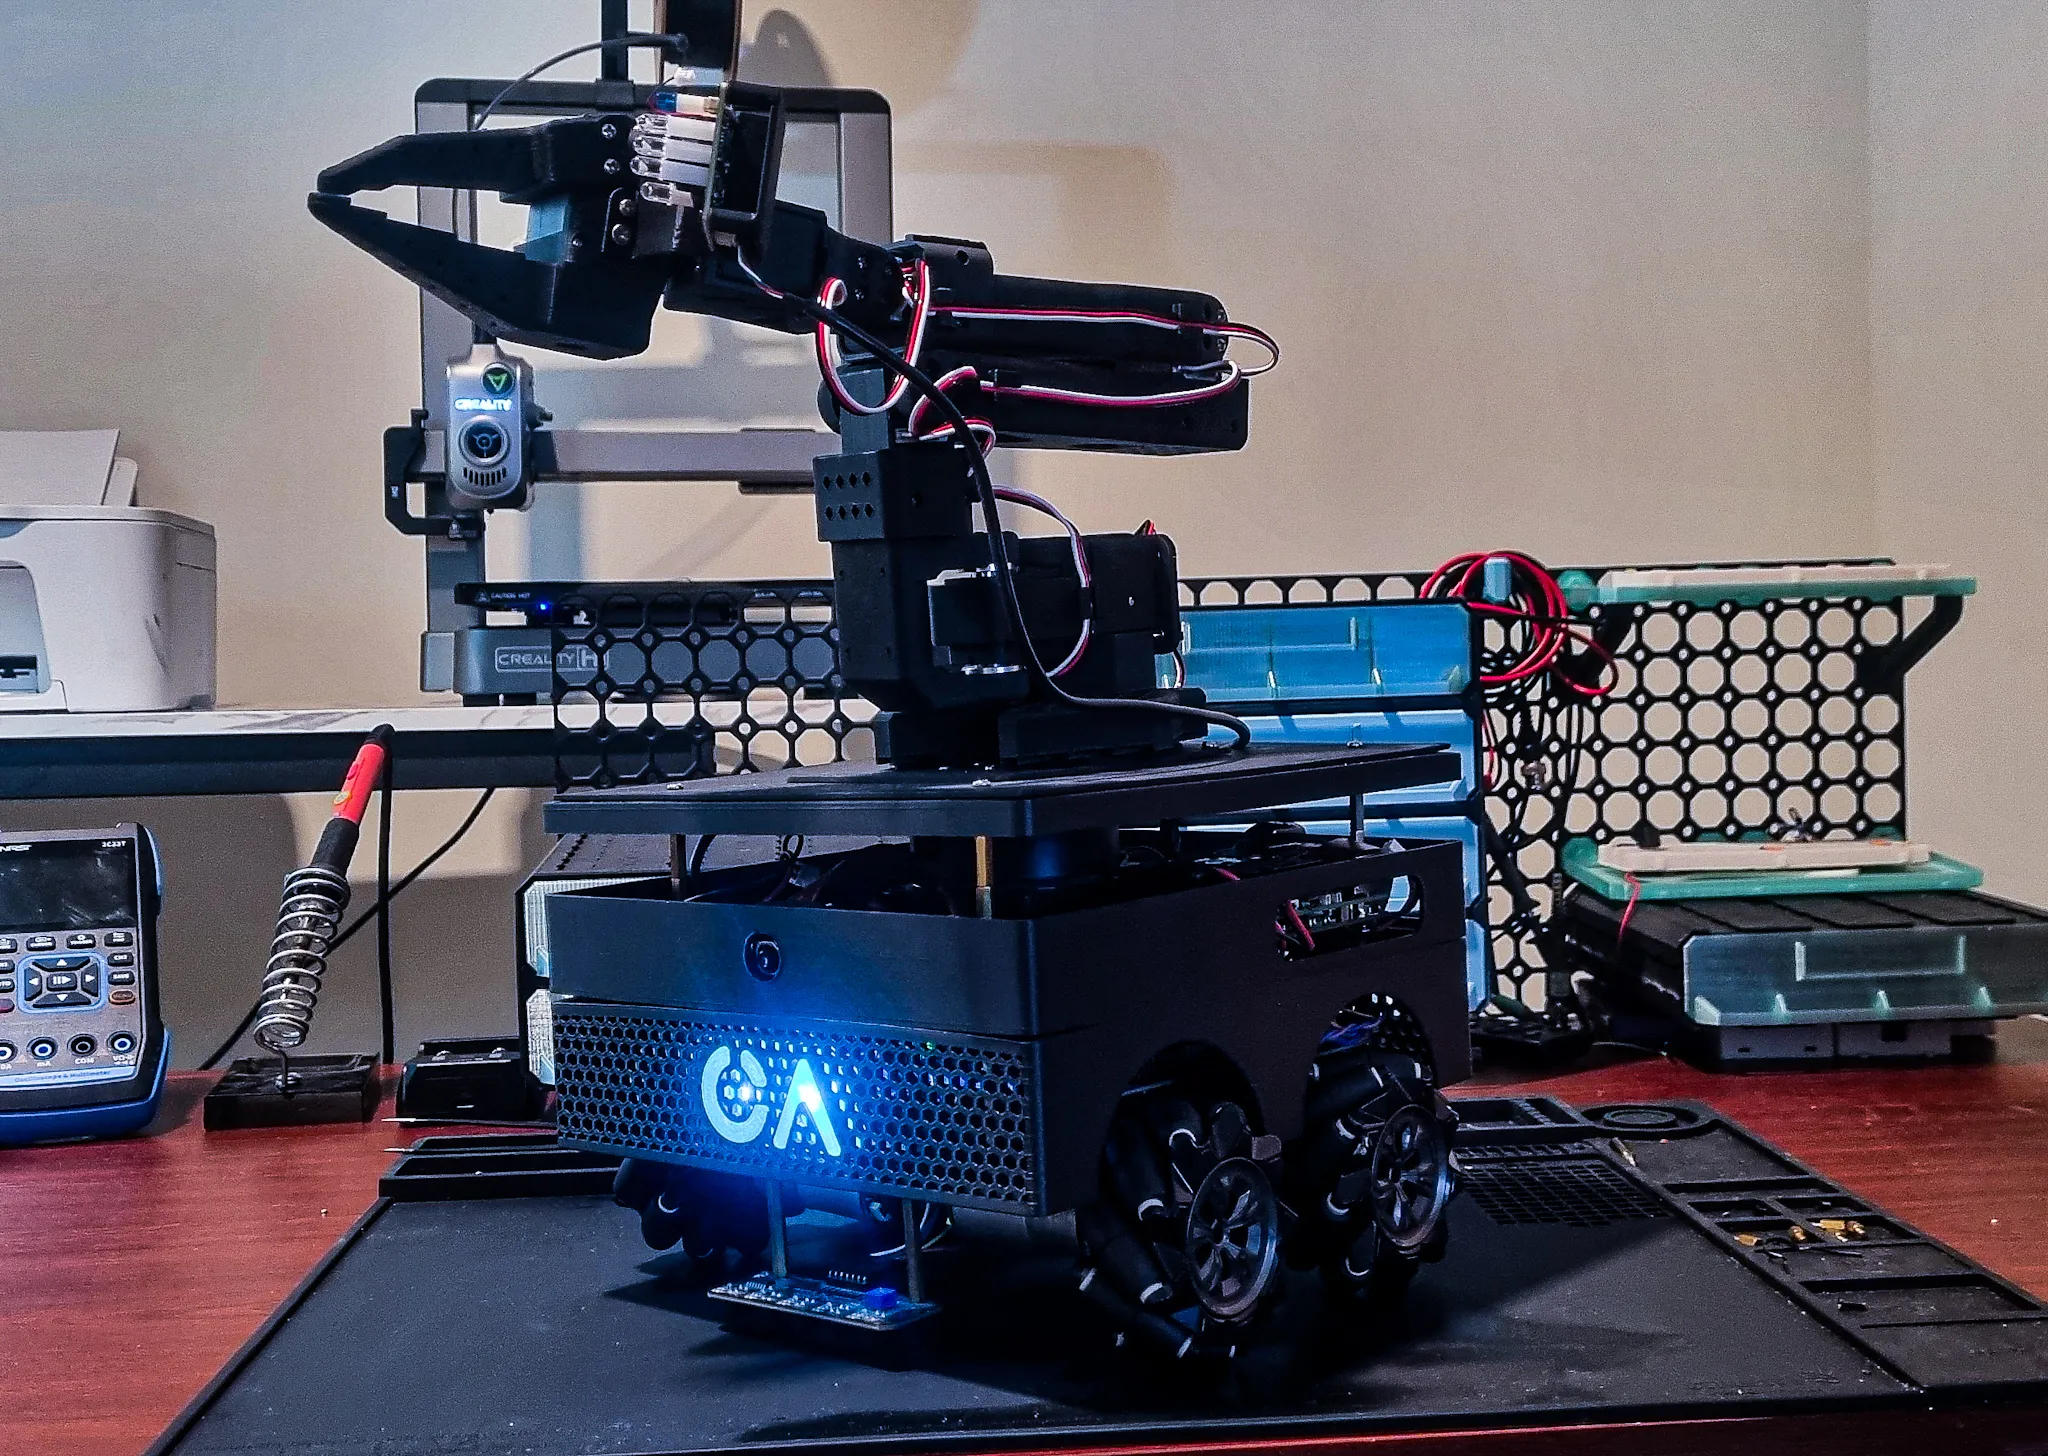
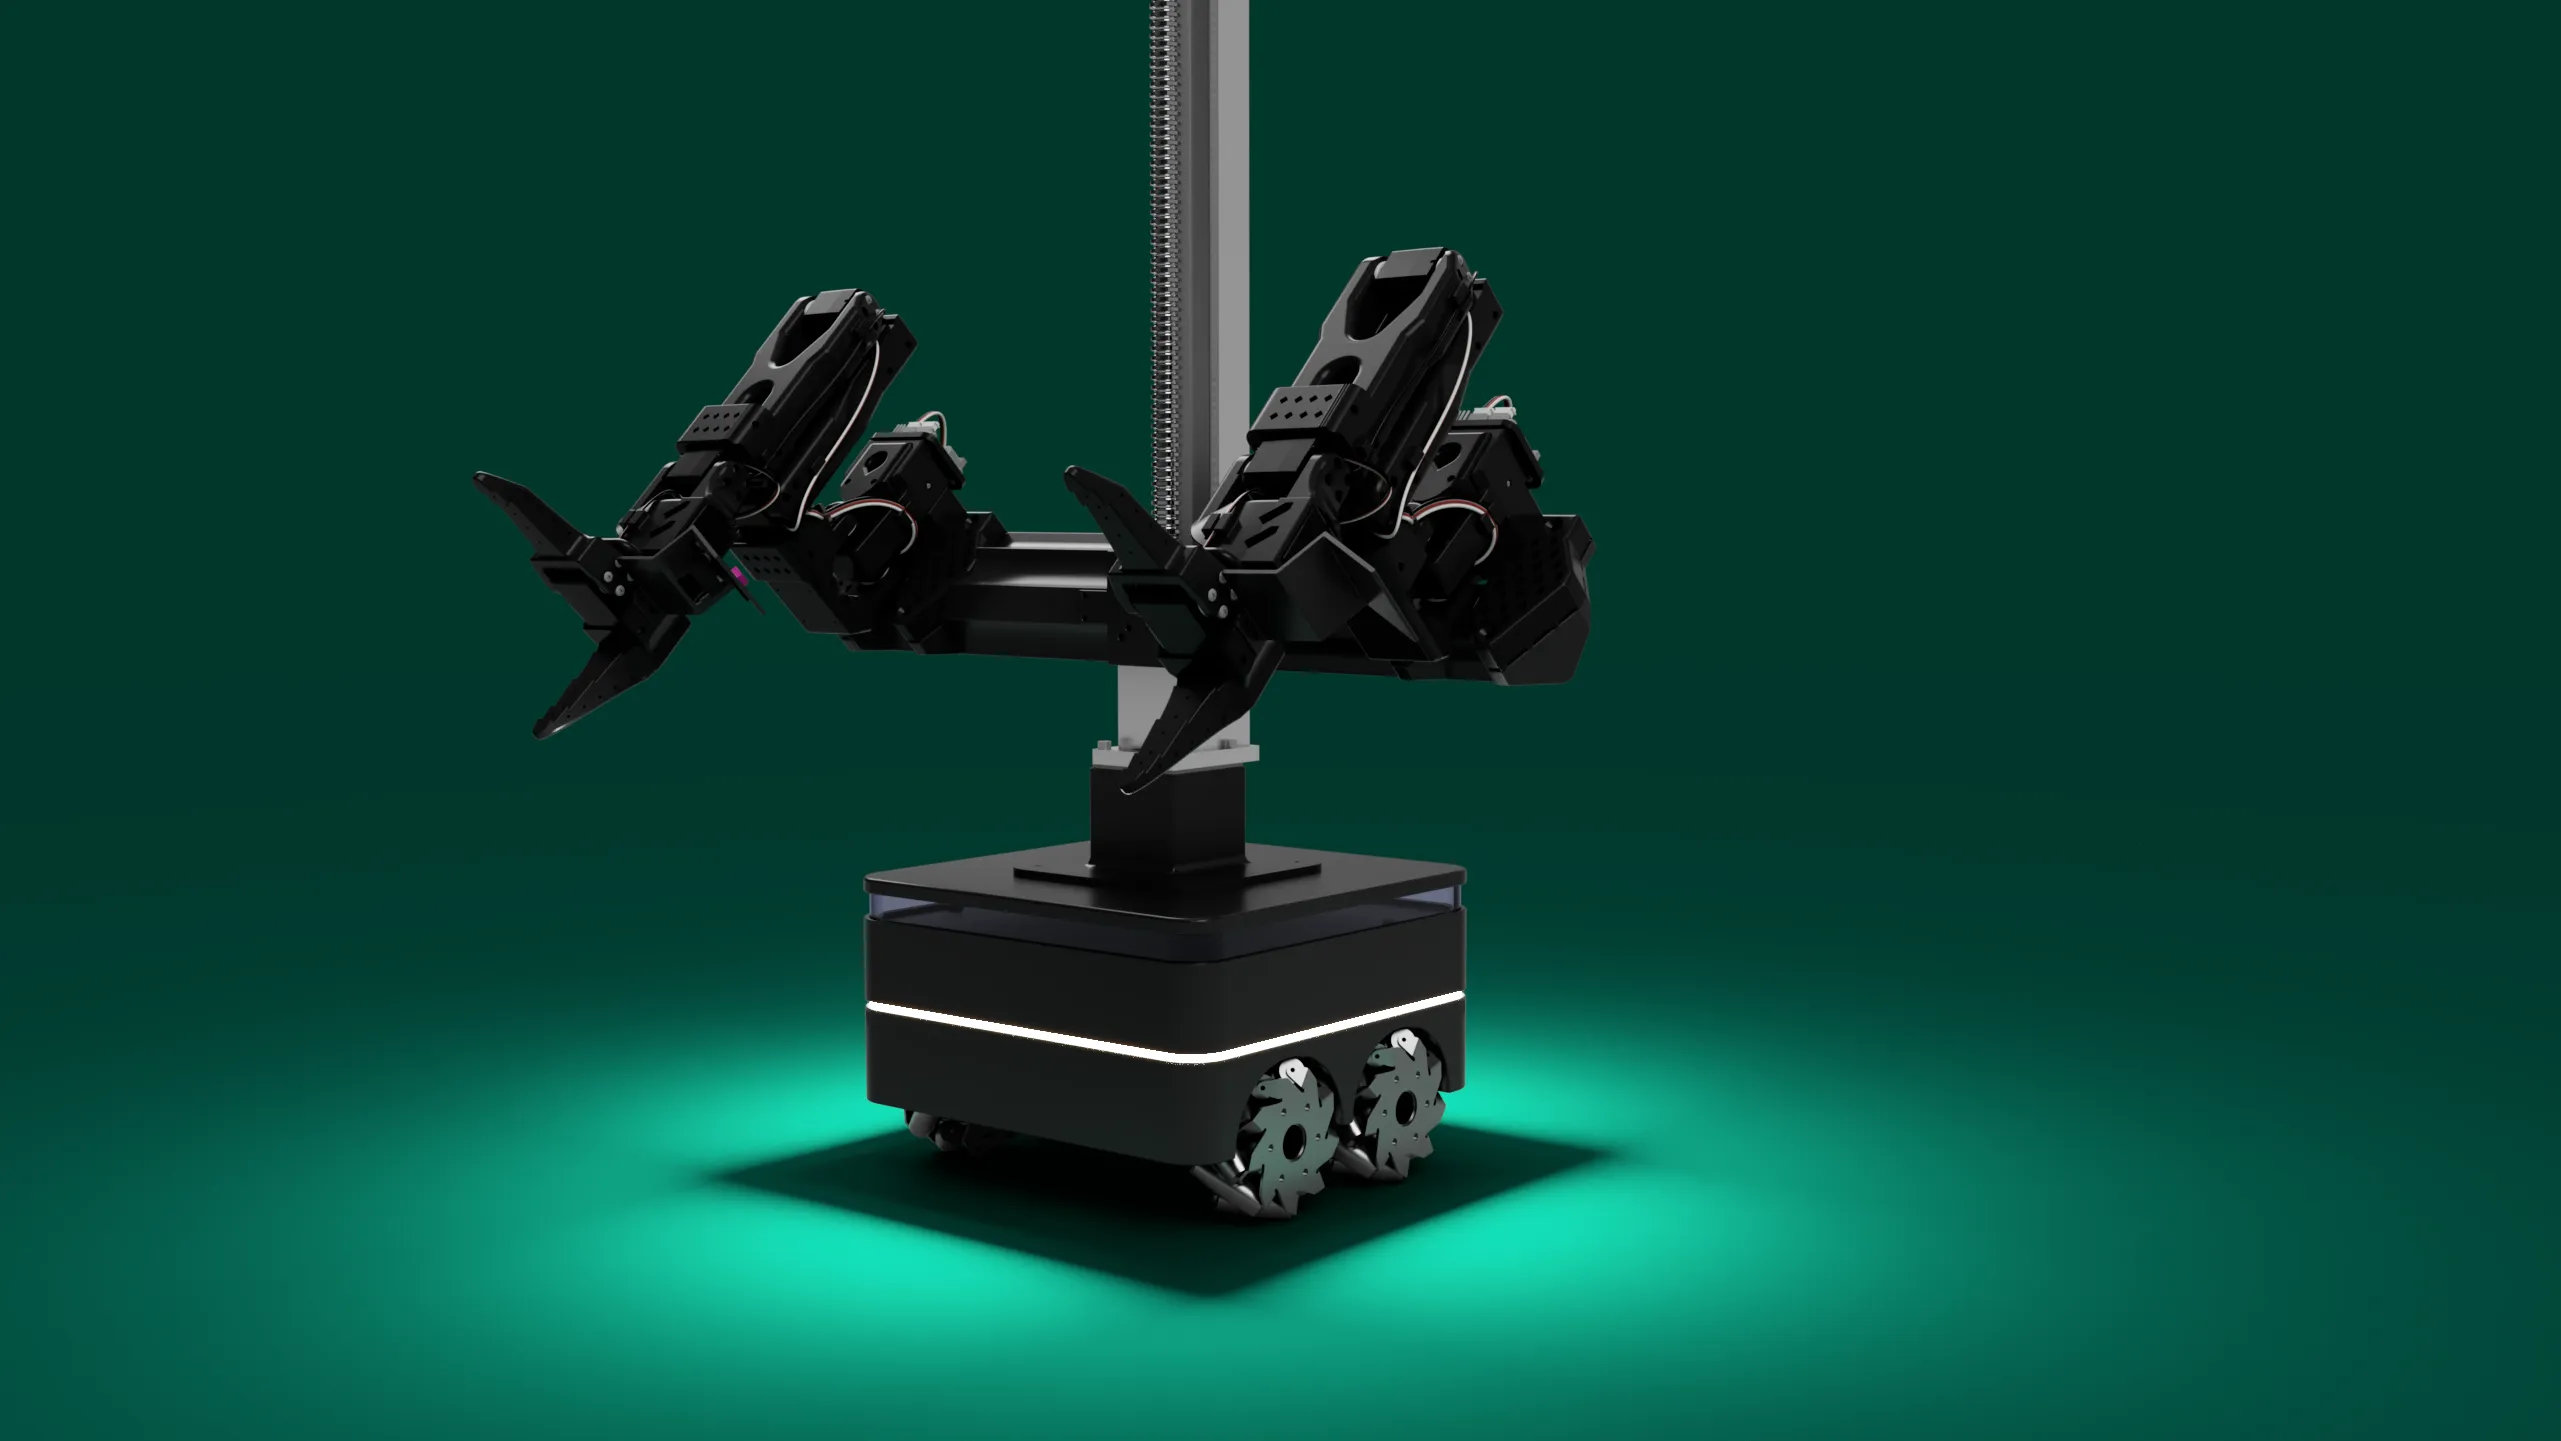
    Genesis: a mobile manipulator, registers to VLA

    Mecanum base, single and dual-arm variants, a whole-body planner that solves on CPU, keypoint perception and a VLA training pipeline. Built from scratch.

    4 min read

  • Personal project

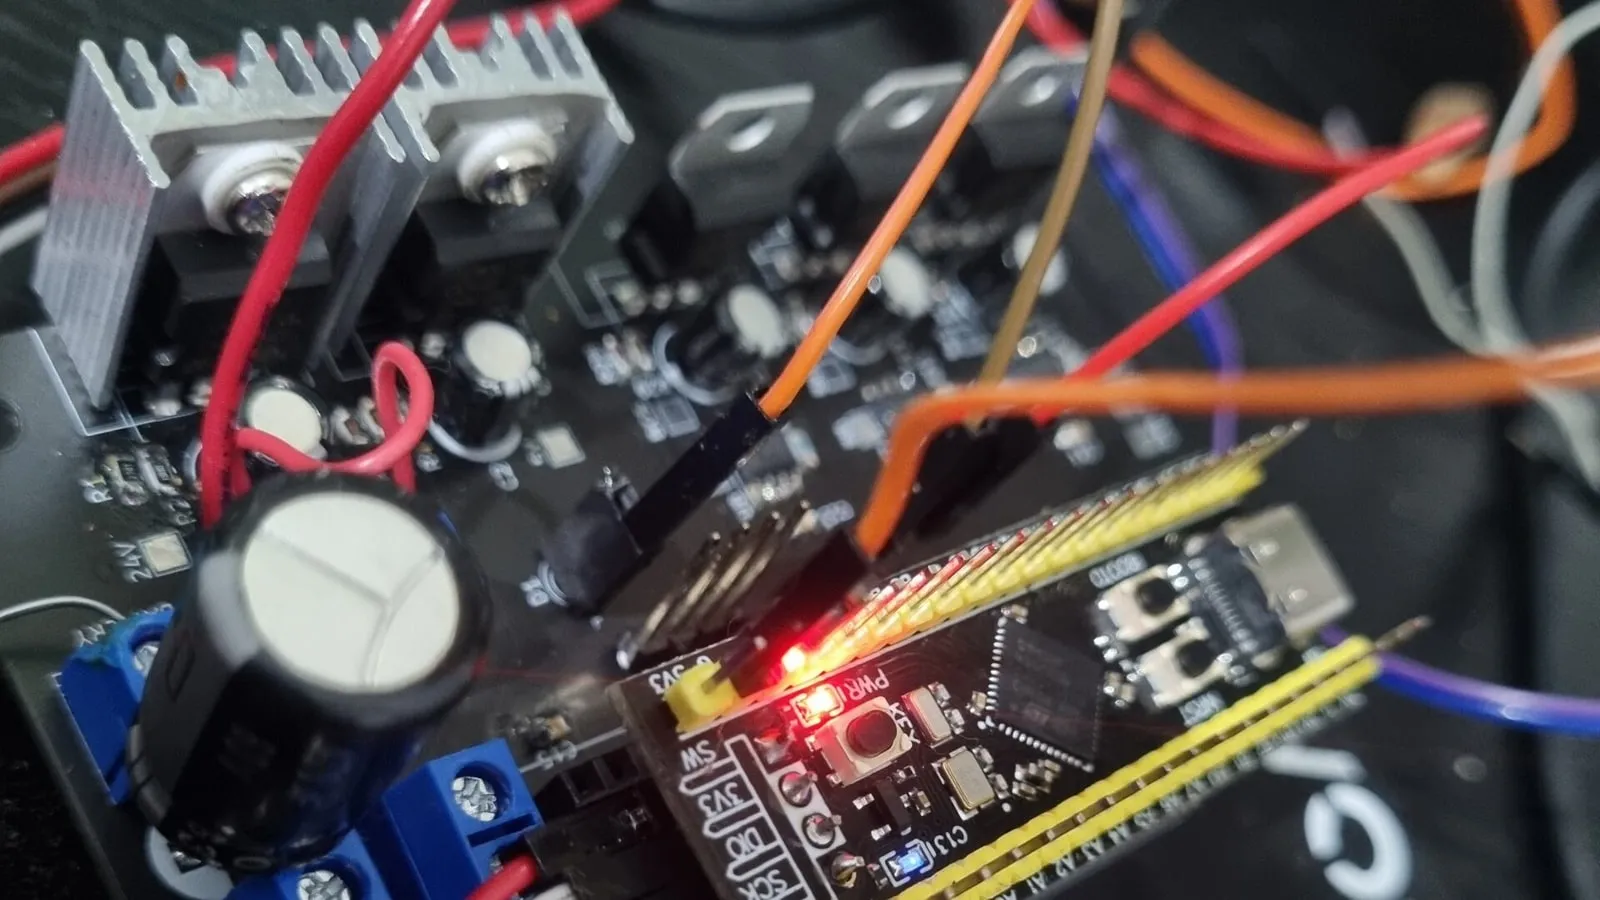
    Sensorless BLDC speed controller

    A custom circuit board and firmware built from scratch to run an e-bike motor without external sensors.

    3 min read

  • Personal project

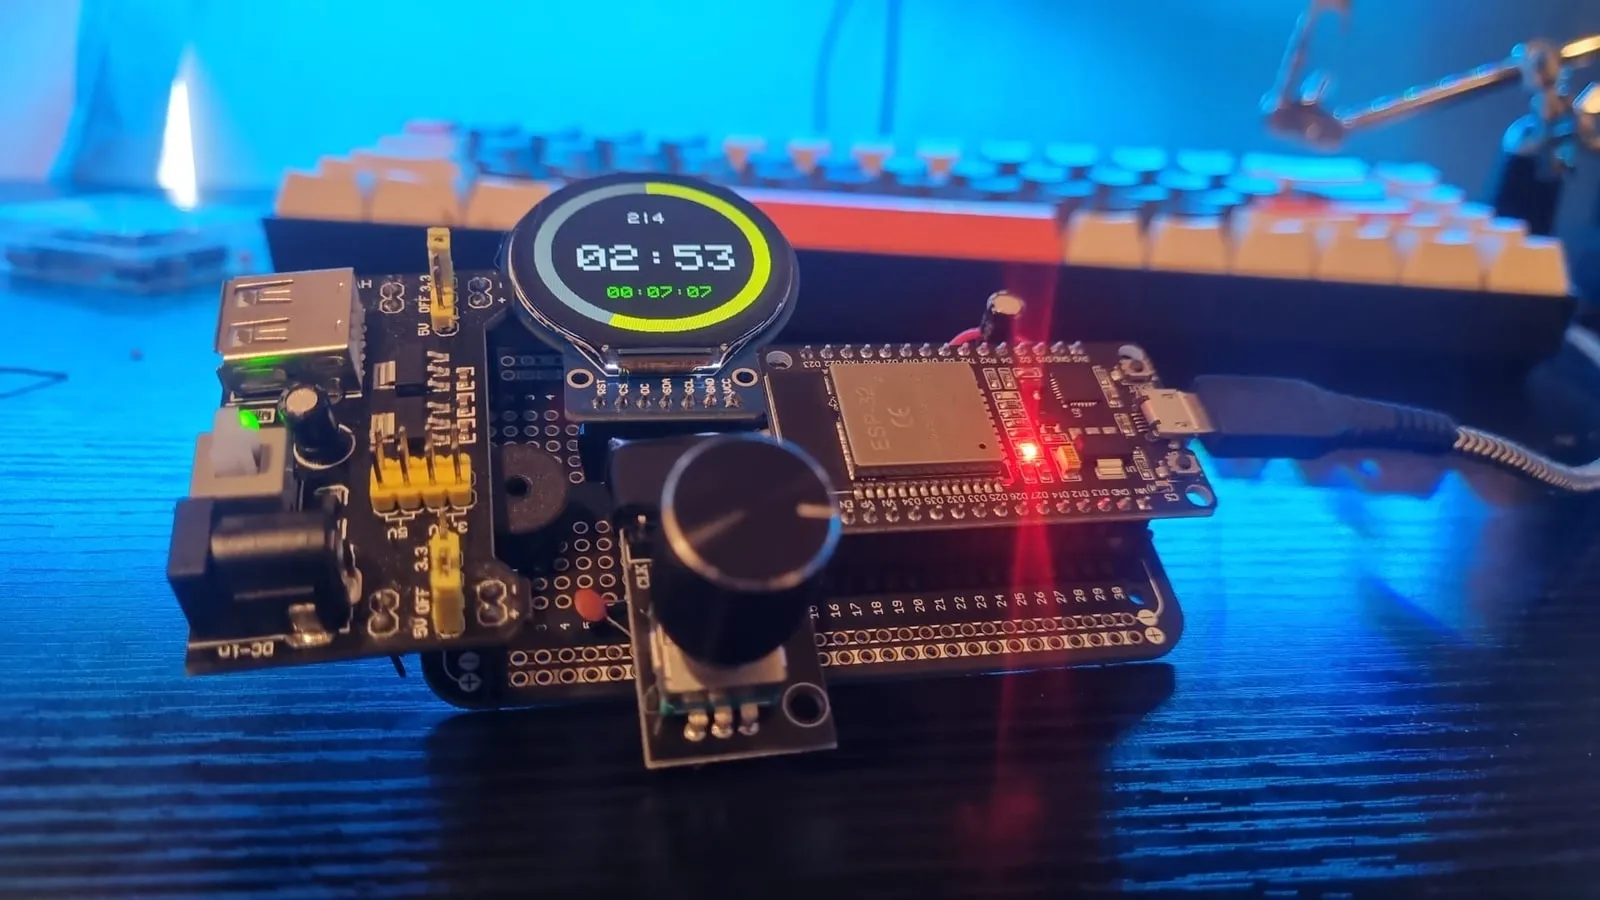
    Multi-app control hub

    A layered C++ framework for ESP32 devices that abstracts hardware logic, letting developers build self-contained knob-driven apps with just four callbacks.

    3 min read

Open to robotics roles

Graduating from Purdue in December 2026. Open to relocation.

Email me