MuJoCo

Used in 2 projects

  • Research at Mars Lab, Purdue University

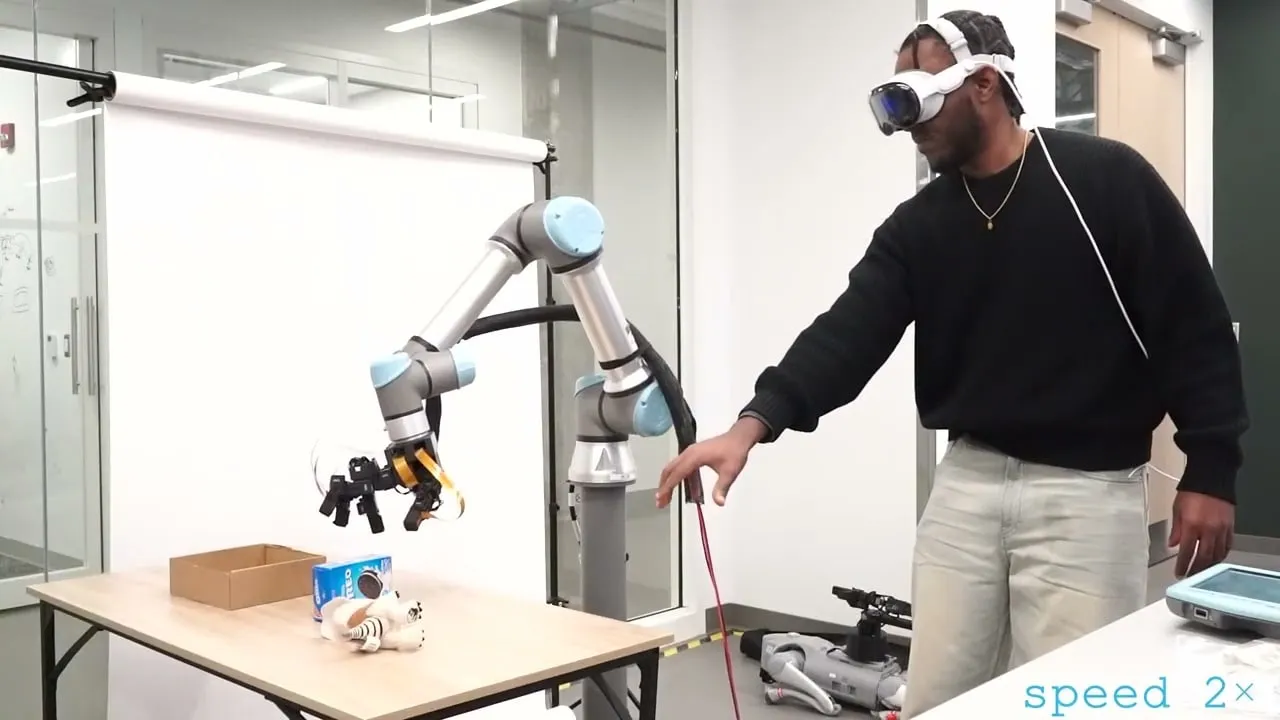
    Dexterous manipulation with full-hand tactile sensing

    Graduate research at the Purdue Mars Lab. I design manipulation tasks, 3D-printed test fixtures, and sensor fusion setups to give a 16-DOF robotic hand a sense of touch.

    • Python
    • MuJoCo
    • ROS 2
    • LEAP Hand
    • Fusion 360

    2 min read

  • Personal project

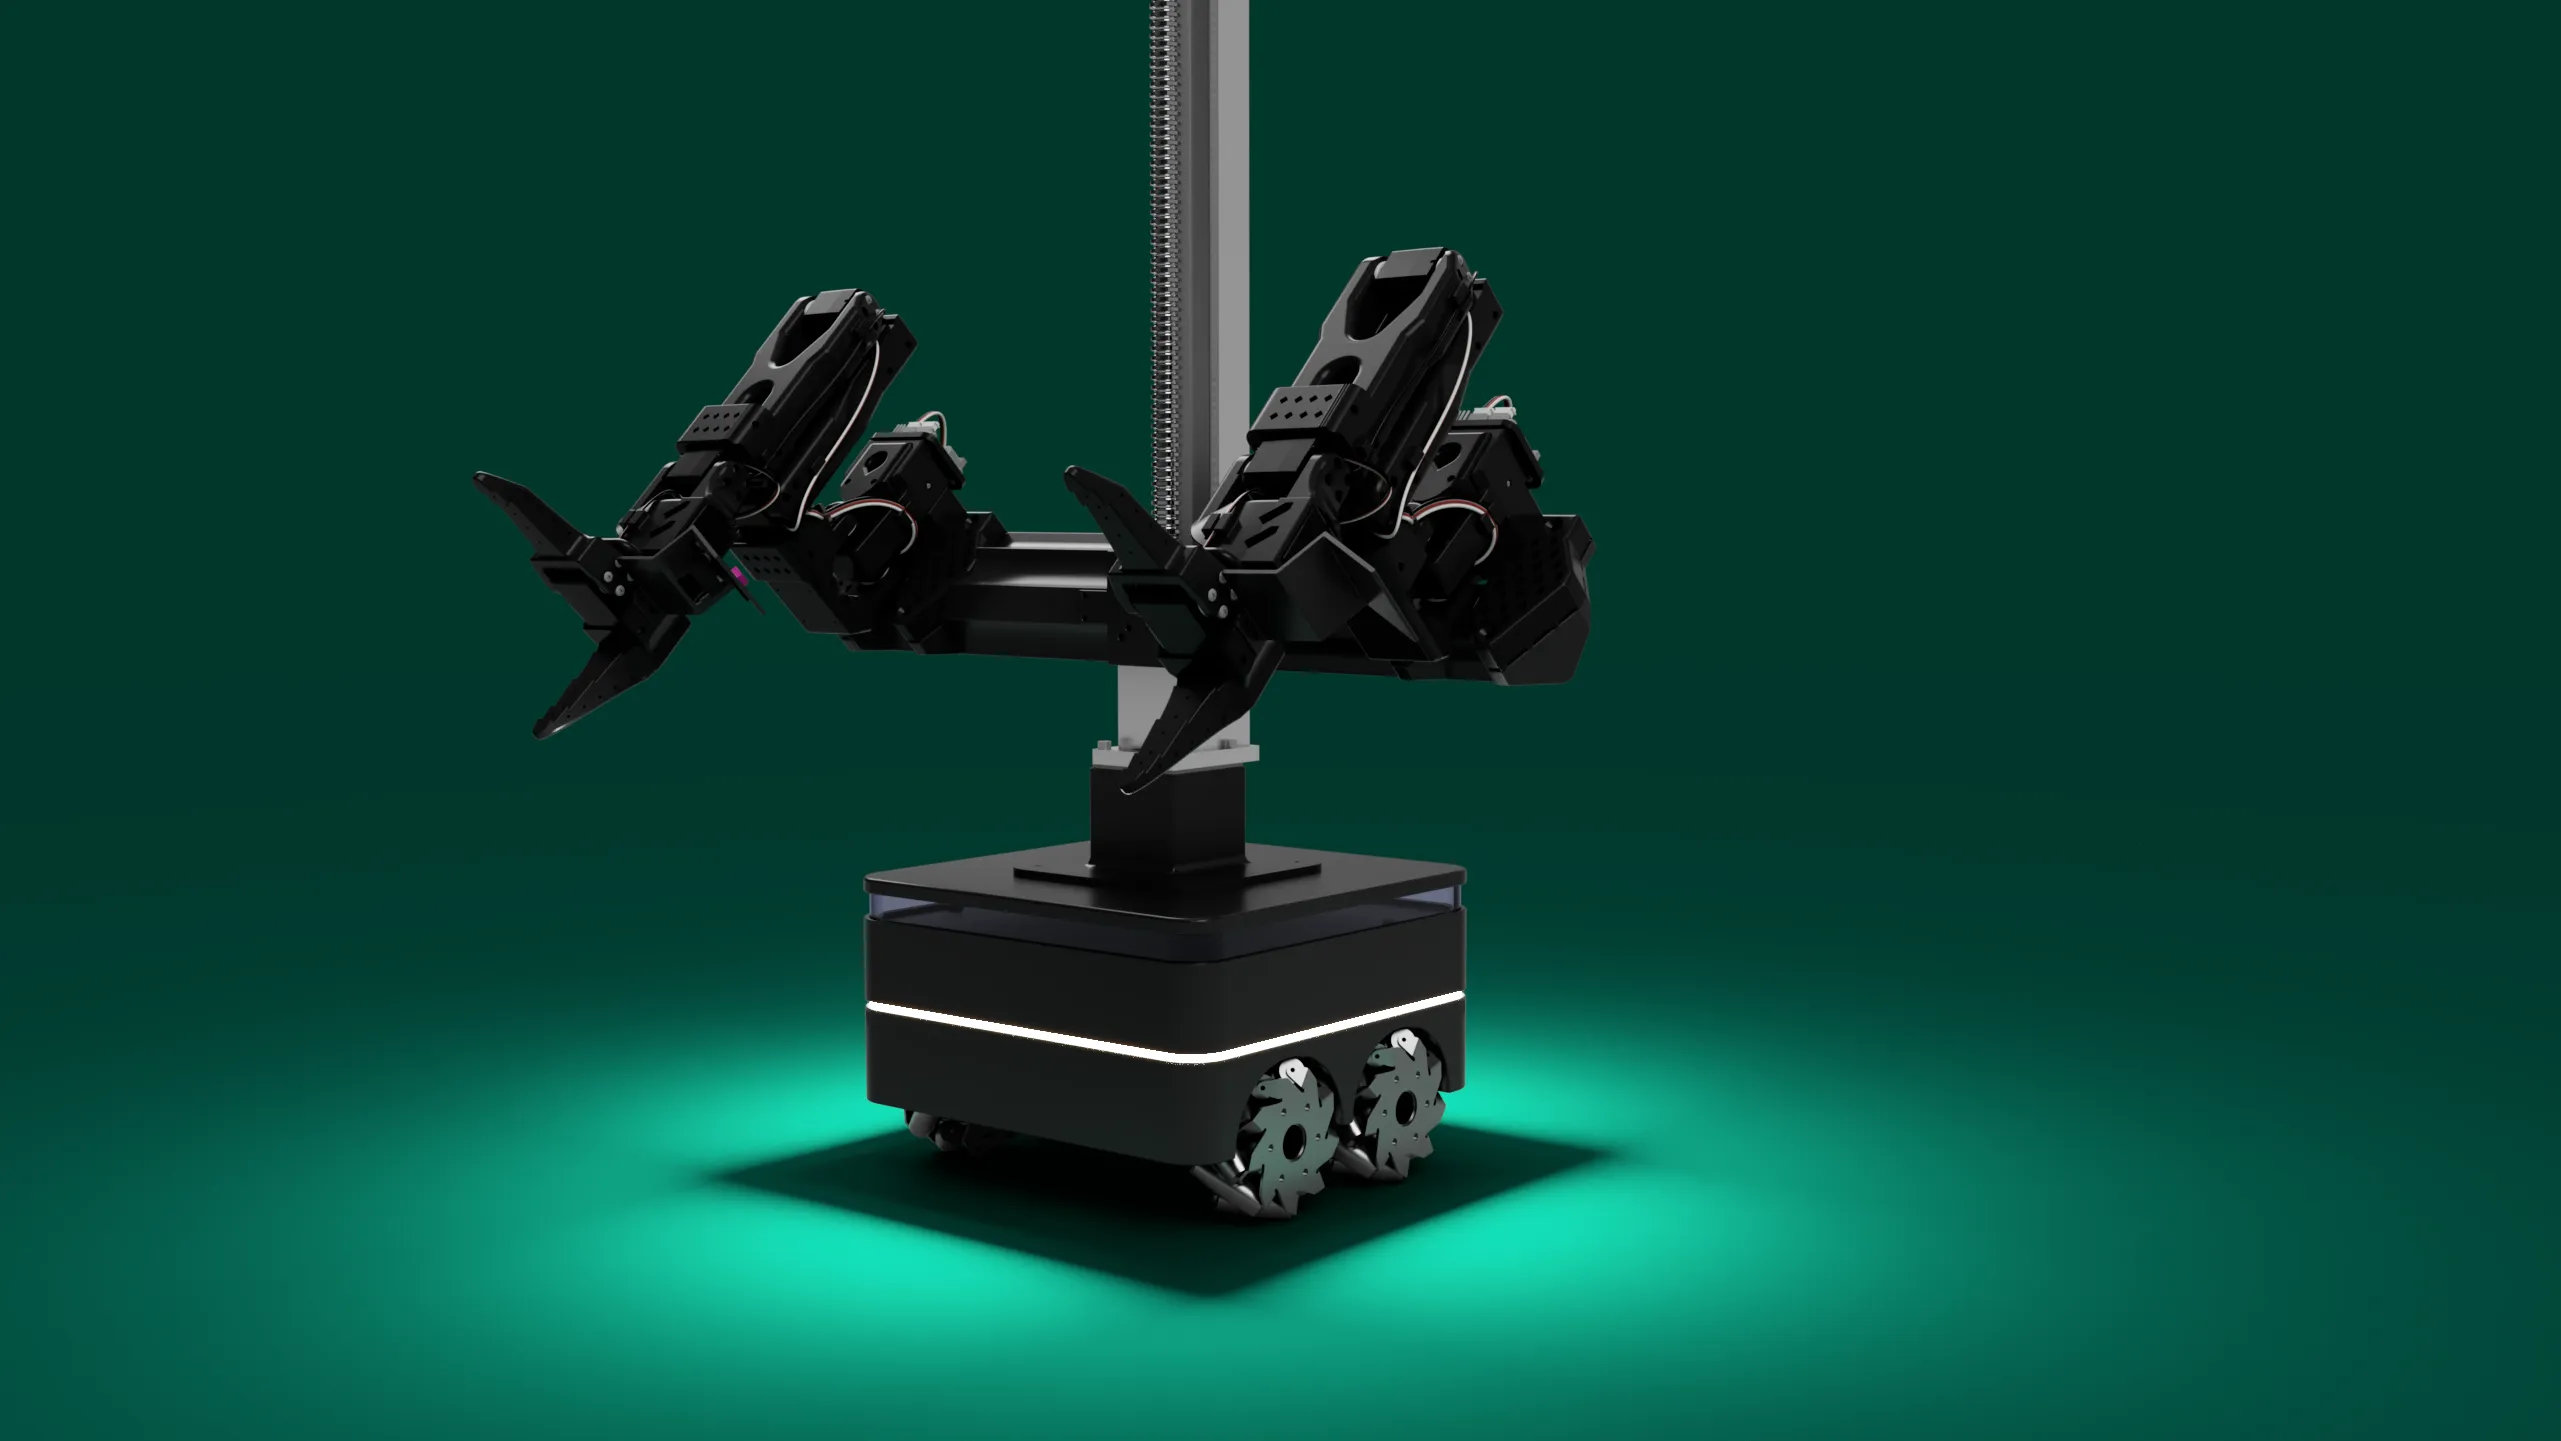
    Genesis: a mobile manipulator, registers to VLA

    Mecanum base, single and dual-arm variants, a whole-body planner that solves on CPU, keypoint perception and a VLA training pipeline. Built from scratch.

    • ROS 2
    • Python
    • C++
    • C
    • OpenCV
    • PyTorch
    • MuJoCo
    • Isaac Sim
    • Gazebo
    • OMPL
    • LeRobot
    • ESP32
    • Raspberry Pi
    • KiCad
    • Fusion 360

    4 min read